FROM PARTS TO SYSTEMS

Projects &
Capabilities项目与能力

Exploring robotics through six connected dimensions.
从六个相互关联的维度,记录机器人学习与实践。

DIMENSION 01

Mechanical Design机械设计

Mechanisms, transmission, fabrication and assembly.

机构、传动、制造与装配。

Experience in this area / 相关经历

My mechanical-design experience centers on an integrated robotic joint: transmission and assembly design, motor optimization, and finite-element analysis.

机械设计经历主要来自一体化机器人关节毕业设计,覆盖传动与总装、电机优化和有限元分析。

  • Transmission & assembly传动与总装Completed independently / 独自完成
  • Motor design & analysis电机设计与分析Completed independently / 独自完成

Projects / 项目

UNDERGRADUATE WORK / 本科期间

Integrated robotic joint design 人形机器人智能关节驱控—结构一体化设计

2024.05Completed / 已完成

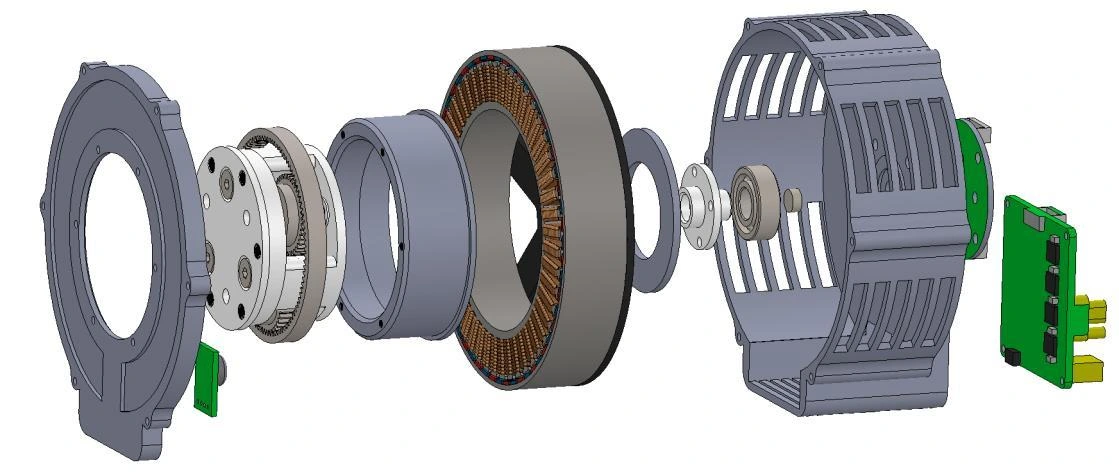
For my undergraduate thesis, I independently designed an integrated humanoid robot joint combining a permanent-magnet synchronous motor, a single-stage planetary gearbox, and drive and sensing components. I compared winding configurations and materials through finite-element analysis, then optimized motor parameters using sensitivity analysis, response-surface models, and a genetic algorithm. Simulation showed about 15% lower peak-to-peak cogging torque and 5% higher average output torque. I completed electromagnetic–thermal analysis, efficiency and loss maps, SolidWorks assembly design, and structural strength checks for a 6:1 quasi-direct-drive joint.

本科毕业设计中,独立完成一体化人形机器人关节方案,将永磁同步电机、一级行星减速器及驱控传感部件集成设计。通过有限元分析比较电机槽极配合与材料,结合灵敏度分析、响应面模型和遗传算法优化电机参数;仿真中齿槽转矩峰峰值降低约 15%,平均输出转矩提高约 5%。完成电磁热耦合分析、效率与损耗图谱、SolidWorks 总装设计及传动结构强度校核,形成减速比 6:1 的准直驱关节方案。
  • mechanical design
  • motor optimization
  • finite-element analysis
Exploded view of the integrated joint, from my undergraduate thesis.
DIMENSION 02

Electronics & Embedded电路与嵌入式

Electronic interfaces, drivers and embedded implementation.

电子接口、驱动与嵌入式实现。

Experience in this area / 相关经历

I independently developed the embedded system for a teleoperation handle, including encoder functionality, motor FOC control, and force-feedback interface design.

我自行完成了遥操作手柄的嵌入式开发,包括编码器相关功能和电机 FOC 控制、力反馈接口设计。

  • Encoder integration编码器开发Completed independently / 独自完成
  • Motor FOC implementation电机 FOC 实现Completed independently / 独自完成
  • UART / ROS & force-feedback interfacesUART/ROS 与力反馈接口Completed independently / 独自完成

Projects / 项目

MASTER’S WORK / 硕士期间

Embedded teleoperation handle 力反馈夹爪 Trigger

Completed / 已完成

I designed and developed a haptic gripper trigger for Franka Panda and integrated it into the teleoperation system. I implemented encoder readout, motor FOC control, and the force-feedback interface so the operator can control the gripper and feel grasp feedback through the trigger. The ESP32 firmware uses SimpleFOC, supports position and torque modes, and communicates with the robot through UART and ROS.

设计并开发了用于控制 Franka Panda 夹爪的力反馈夹爪 Trigger,并接入遥操作系统。独立完成编码器读取、电机 FOC 控制与力反馈接口,使操作者能够通过 Trigger 控制夹爪,并感受抓取反馈。固件基于 ESP32 和 SimpleFOC,支持位置与力矩模式切换,通过 UART 和 ROS 与机器人通信。

  • ESP32
  • C++ / FreeRTOS
  • SimpleFOC
  • I²C / SPI / UART
  • ROS

Integrated robotic joint design

Selection of the motor driver, magnetic encoder and temperature sensor within the joint design.

关节方案中的驱动板、磁编码器与温度传感器选型。

DIMENSION 03

Control & Optimization控制与优化

Control, motion planning, trajectory generation and optimization.

控制、运动规划、轨迹生成与优化。

Experience in this area / 相关经历

My current projects focus on variable-impedance control for robot arms and motor control.

目前项目集中于机械臂变阻抗控制与电机控制。

  • Impedance retargeting阻抗重定向Completed independently / 独自完成
  • Constrained optimization约束优化Completed independently / 独自完成
  • Panda variable-impedance controlPanda 变阻抗控制Completed independently / 独自完成

Projects / 项目

MASTER’S WORK / 硕士期间

CMDIR 连续阻抗重定向与模仿学习

Submitted / 在投

I study how fixed-impedance teleoperation demonstrations can become continuous variable-impedance policies for learning. CMDIR introduces a continuous task-manifold impedance representation and Quality-to-Fast optimization to adjust contact behavior while preserving task response, then uses the optimized controllers to supervise imitation learning. I implemented demonstration retargeting, policy training, and robot execution, with experiments on planar wiping, curved wiping, and pushing.

研究如何把固定阻抗遥操作示教转化为可用于学习的连续变阻抗控制策略。提出连续任务流形阻抗表示和 Quality-to-Fast 优化方法,在保持任务响应的同时调整接触行为,并用优化后的控制器监督模仿学习。完成从示教重定向、策略训练到机器人执行的实现,在平面擦拭、曲面擦拭和推动任务中开展实验。

  • impedance control
  • retargeting
  • imitation learning

MASTER’S WORK / 硕士期间

MDIR 任务流形阻抗重定向

Submitted / 在投

I developed task-manifold impedance retargeting to turn fixed-impedance demonstrations into variable-impedance controllers for contact tasks. The method separates work, exertion, and support requirements to moderate contact while preserving task response. I implemented the method and evaluated it on Franka Panda in planar wiping, pick-and-place, and pushing tasks.

提出任务流形阻抗重定向方法,将固定阻抗示教转化为适合接触任务的变阻抗控制器。方法按工作、施力和支撑的不同需求组织控制,在保留任务响应的同时减缓接触冲击。完成方法实现及 Panda 实机实验,验证于平面擦拭、抓放和推动任务。

  • impedance control
  • teleoperation
  • retargeting

TRACT

A causal response-deficit integrator addresses suppressed motion during contact execution.

通过因果响应不足积分器处理接触执行中的运动受阻。

MASTER’S WORK / 硕士期间

Franka Panda impedance control Franka Panda 变阻抗控制

I developed a Cartesian variable-impedance controller for Franka Panda, used for force-feedback teleoperation, demonstration replay, and learned-policy execution. It supports task-space stiffness and damping adjustment, null-space posture control, torque-rate limiting, and synchronized pose and impedance commands across contact-manipulation experiments.

为 Franka Panda 开发笛卡尔变阻抗控制器,用于力反馈遥操作、示教回放和学习策略执行。实现任务空间刚度与阻尼调节、零空间姿态控制和力矩变化率限制,支持位姿与阻抗同步下发,让同一套控制器服务于不同接触操作实验。

  • variable impedance
  • robot kinematics
  • motor torque control
Compliant response to an external push.

Embedded teleoperation handle

Motor FOC control and force-feedback interface design for the teleoperation handle.

遥操作手柄的电机 FOC 控制与力反馈接口设计。

Panda simulation & policy evaluation

Implemented Cartesian PD+ calculations corresponding to the hardware controller and physical command replay.

实现与实机控制公式对应的笛卡尔 PD+ 计算与物理命令回放。

DIMENSION 04

Machine Learning机器学习

Learning perception, representations and behavior from data.

从数据学习感知、表示与行为。

Experience in this area / 相关经历

My work on robot imitation learning includes reproducing commonly used models such as ACT, Flow Matching, and PI0.5, alongside several research projects.

围绕机器人模仿学习进行了若干工作:复现 ACT、Flow Matching、PI0.5 等常用模型,并进行了若干研究。

  • Imitation learning模仿学习Completed independently / 独自完成
  • ACT / Flow Matching / π0.5ACT / Flow Matching / π0.5 复现Completed independently / 独自完成

Projects / 项目

MASTER’S WORK / 硕士期间

TRACT 面向接触操作的时序动作块

Submitted / 在投

I study phase transitions and stalled motion in action-chunk prediction for multi-stage contact-rich manipulation. TRACT routes predicted actions by task phase and uses a response-deficit integrator to compensate for motion suppressed by contact. I implemented training, inference, and hardware deployment and evaluated the method in multi-stage wiping.

面向多阶段富接触操作,研究动作块预测中的阶段切换与接触受阻问题。提出按任务阶段路由动作的模仿学习策略,并结合响应不足积分器补偿接触中的运动受阻。完成模型训练、推理与实机部署,在多阶段擦拭任务中验证。

  • imitation learning
  • action chunking
  • contact-rich manipulation

CMDIR

Using retargeted TMIR controllers as structured imitation-learning supervision.

使用重定向后的 TMIR 控制器作为结构化模仿学习监督。

MASTER’S WORK / 硕士期间

ACT · Flow Matching · π0.5 机器人学习算法复现

Completed / 已完成

I independently reproduced ACT, Flow Matching, and PI0.5, working on training, inference, and deployment for robot imitation learning. I integrated these models into my experimental platform for method comparisons and further research.

独立复现 ACT、Flow Matching 和 PI0.5,开展机器人模仿学习模型的训练、推理与部署工作,并接入自己的实验平台,用于方法对比与后续研究。

  • ACT
  • Flow Matching
  • π0.5

UNDERGRADUATE WORK / 本科期间

Tohoku University · YOLOv8 garment grasping 东北大学 · 基于 YOLOv8 的衣物视觉抓取

2023.10 – 2024.03Completed / 已完成

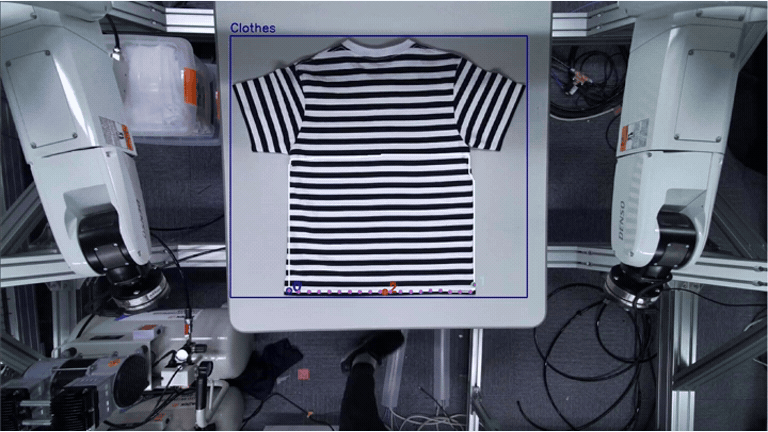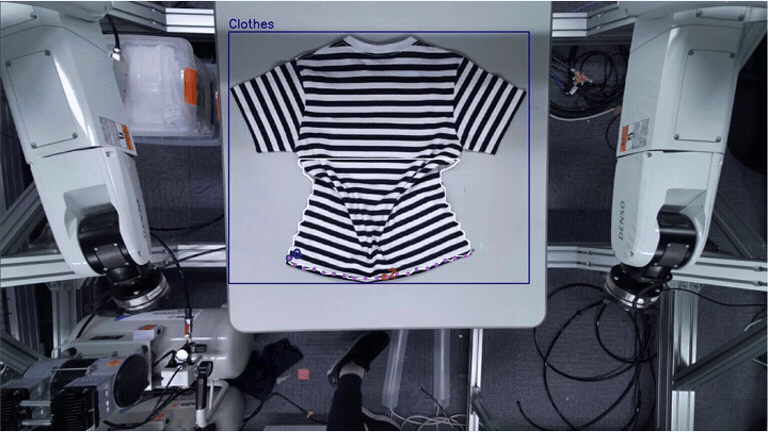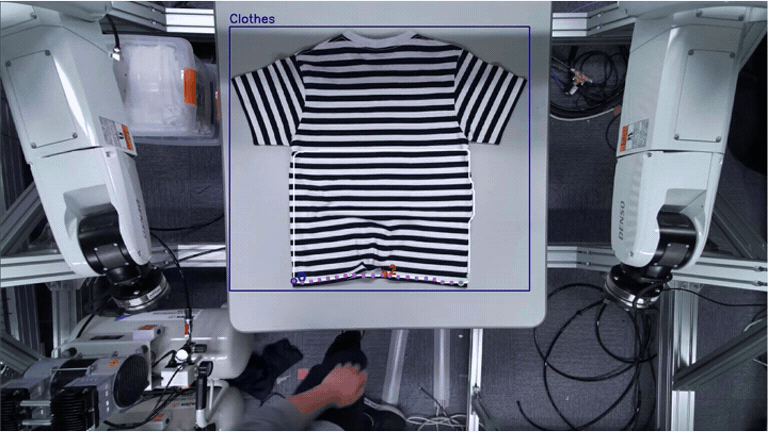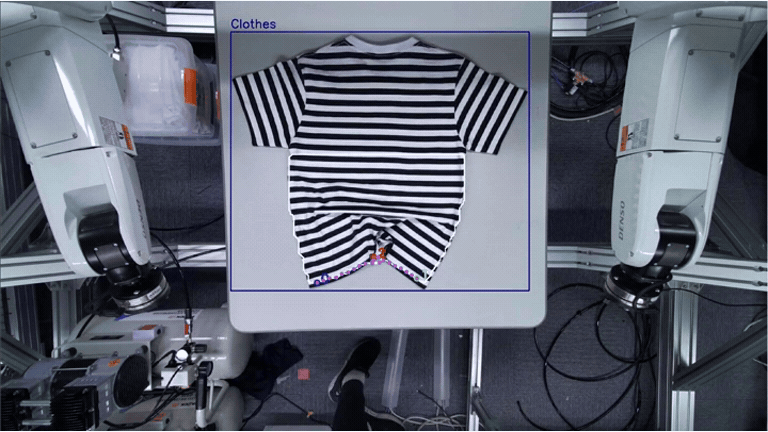
During my exchange at the Smart Robot Design Lab, Tohoku University, I used YOLOv8, a purpose-built dataset, and a coupled two-model approach to extract garment hem points for robotic visual grasping.

在东北大学 Smart Robot Design Lab 交换期间,基于 YOLOv8、自建数据集与双模型结合方法提取衣物下摆特征点,用于机器人衣物视觉抓取。

  • YOLOv8
  • visual grasping
  • garment manipulation
Garment keypoint detection in the Tohoku University project.

Panda simulation & policy evaluation

Connected policy inference to simulation rollouts with task randomization, perturbation injection, and evaluation.

连接策略推理与仿真 rollout,支持任务随机化、扰动注入和评估。

DIMENSION 05

Mathematical Foundations数理理论

Robotics, coordinate transforms and Jacobians, dynamics identification, continuous representations, and constrained optimization.

机器人学、坐标变换与雅可比、动力学辨识,以及连续表示和约束优化。

Experience in this area / 相关经历

Drawing on robotics foundations, I use task-coordinate representations, dynamics, and constrained optimization in contact-control research, and have contributed quantitative dynamics analysis of human walking stability.

以机器人学为基础,在接触控制研究中使用任务坐标表示、动力学与约束优化;参与过人体步行稳定性的动力学定量分析。

  • Robotics, transforms & dynamics机器人学、坐标变换与动力学Completed independently / 独自完成
  • Calibration & parameter identification标定与参数辨识Completed independently / 独自完成
  • Continuous representations & constrained optimization连续表示与约束优化Completed independently / 独自完成

Projects / 项目

CMDIR

Continuous task frames, response criteria and constrained parameter fields.

连续任务坐标、响应准则与受约束参数场。

MDIR

Task-channel representation, response preservation and constrained parameter optimization.

任务通道表示、响应保留与约束参数优化。

Franka Panda impedance control

Robot kinematics, Jacobians, and null spaces in variable-impedance control.

机械臂运动学、雅可比与零空间在变阻抗控制中的应用。

Force-feedback teleoperation framework

Hand–eye calibration, sensor payload identification, and force-coordinate transformations for the teleoperation platform.

遥操作平台中的手眼标定、传感器负载辨识与力坐标变换。

UNDERGRADUATE WORK / 本科期间

Suspended backpack stability 悬浮背包稳定性与能耗研究

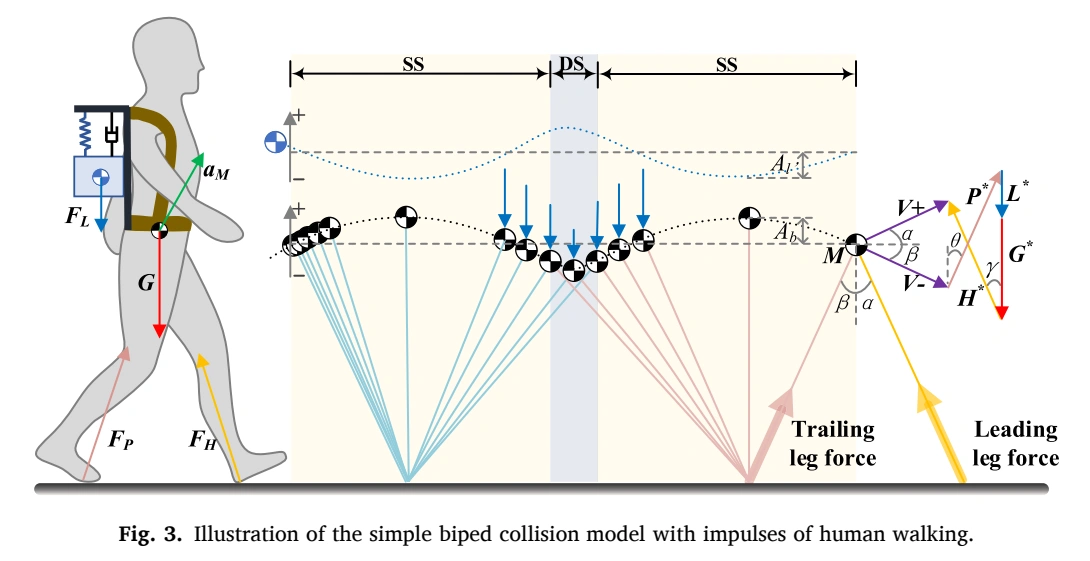
I studied how load fluctuations in suspended backpacks affect human walking stability and energy expenditure, contributing experimental data analysis and quantitative dynamics modeling. The work was published in Mechanical Systems and Signal Processing and informs backpack performance evaluation and design optimization.

研究悬浮背包的负载波动如何影响人体步行稳定性与能耗,承担实验数据分析与动力学定量建模。成果发表于 Mechanical Systems and Signal Processing,为悬浮背包的性能评价与优化设计提供依据。

  • biomechanics
  • stability analysis
  • data analysis
Biped walking model. Fig. 3, page 7 of the MSSP paper.
DIMENSION 06

System Integration系统集成

Bringing mechanics, embedded systems, control, and learning together into complete robot systems that work on real tasks.

将机械、嵌入式、控制与学习整合为完整的机器人系统,并在实际任务中运行。

Experience in this area / 相关经历

Built force-feedback teleoperation and general-purpose policy deployment frameworks connecting sensor calibration, multimodal demonstration collection, dataset conversion, policy inference, real-robot execution, and Isaac Lab simulation.

构建力反馈遥操作 Framework 与通用策略部署 Framework,贯通传感器标定、多模态示教采集、数据集转换、策略推理、实机执行和 Isaac Lab 仿真。

  • Force-feedback teleoperation力反馈遥操作Completed independently / 独自完成
  • Policy deployment策略部署Completed independently / 独自完成
  • Data pipelines & simulation platform数据链路与仿真平台Completed independently / 独自完成
  • Hand–eye & force-sensor calibration手眼与力传感器标定Completed independently / 独自完成

Projects / 项目

MASTER’S WORK / 硕士期间

Force-feedback teleoperation framework 力反馈遥操作 Framework

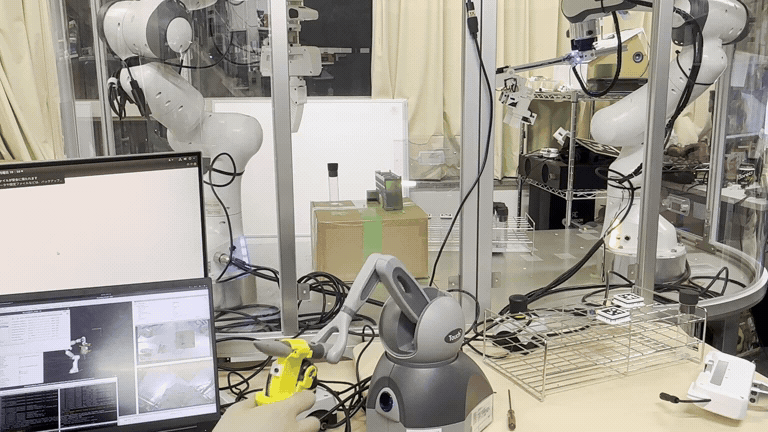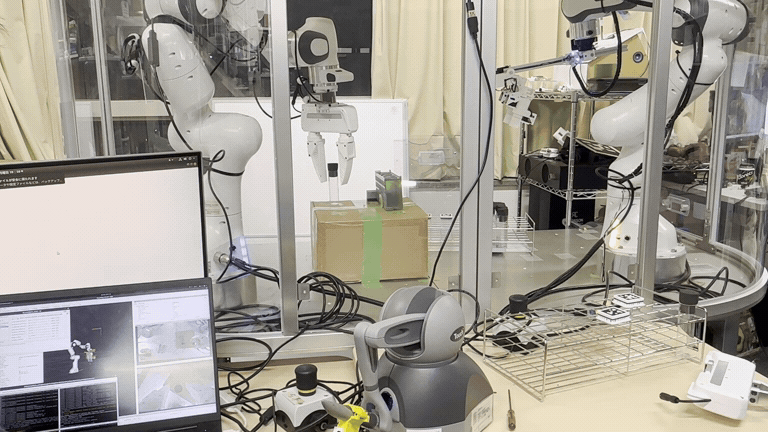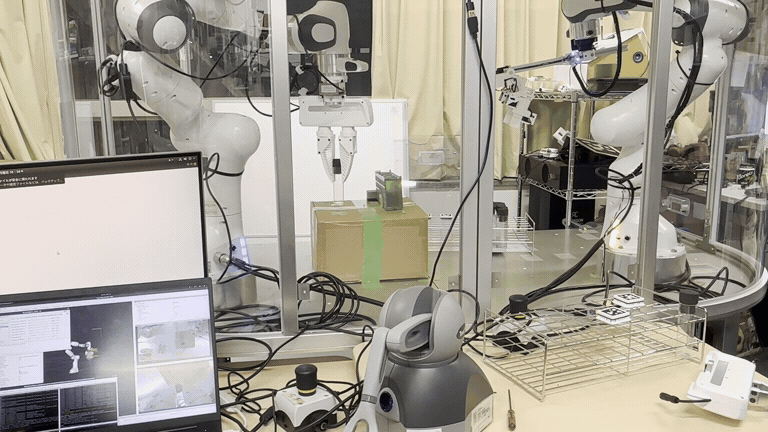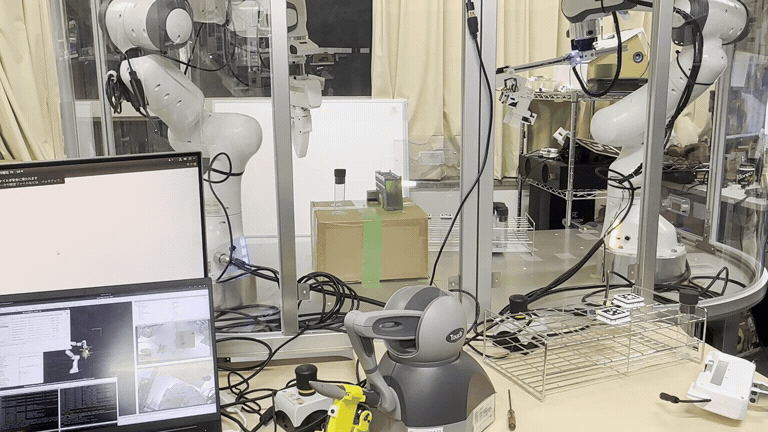
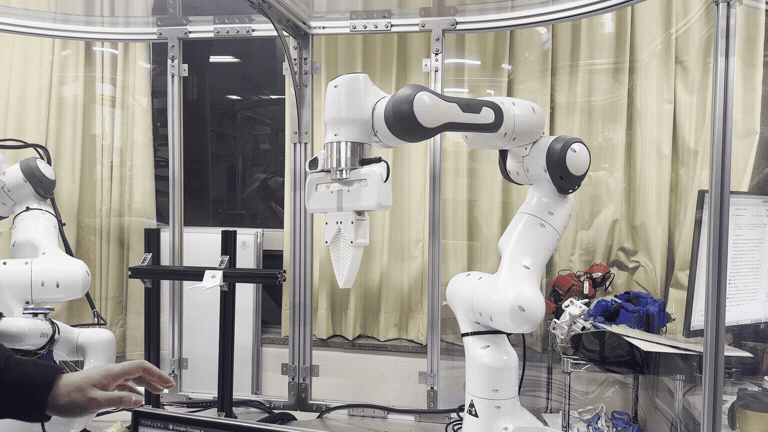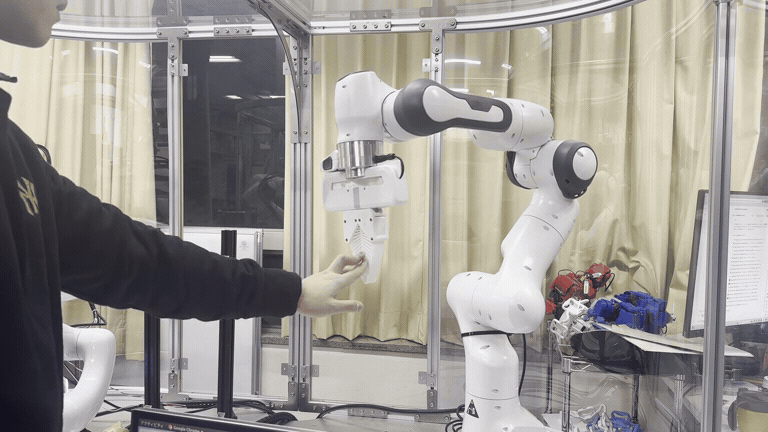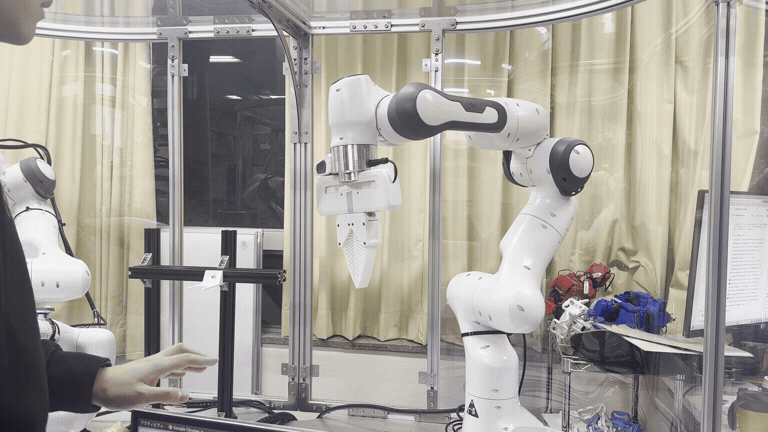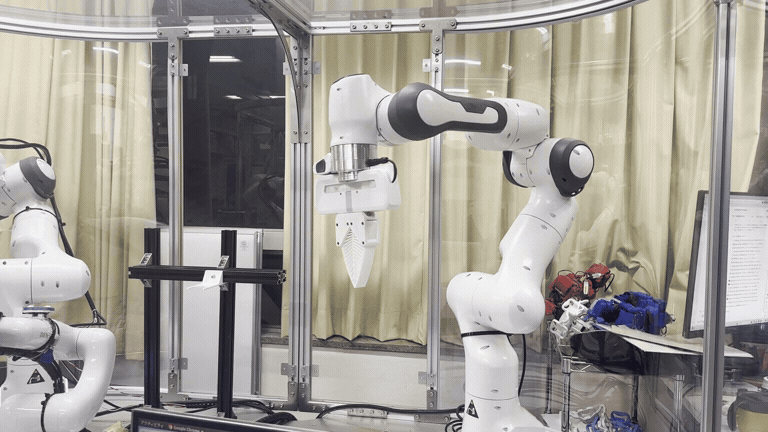
I built and continue to maintain a robot platform that reliably collects force-feedback teleoperation demonstrations for contact-rich tasks. It combines Franka Panda, Geomagic Touch, and a custom haptic gripper trigger for coordinated arm and gripper operation. I implemented hand–eye and force-sensor payload/bias calibration, with synchronized multi-view images, robot states, and contact forces for control and imitation-learning research.

自主搭建并长期维护力反馈遥操作机器人平台,稳定采集富接触任务的示教数据。平台以 Franka Panda 和 Geomagic Touch 为主体,接入自研力反馈夹爪 Trigger,实现机械臂与夹爪的协同遥操作。完成手眼标定、力传感器负载与零偏标定,并同步记录多视角图像、机器人状态和接触力,用于控制与模仿学习研究。

  • haptic teleoperation
  • sensor calibration
  • demonstration collection
Force-feedback teleoperation with Franka Panda.

MASTER’S WORK / 硕士期间

General-purpose policy deployment framework 通用策略部署 Framework

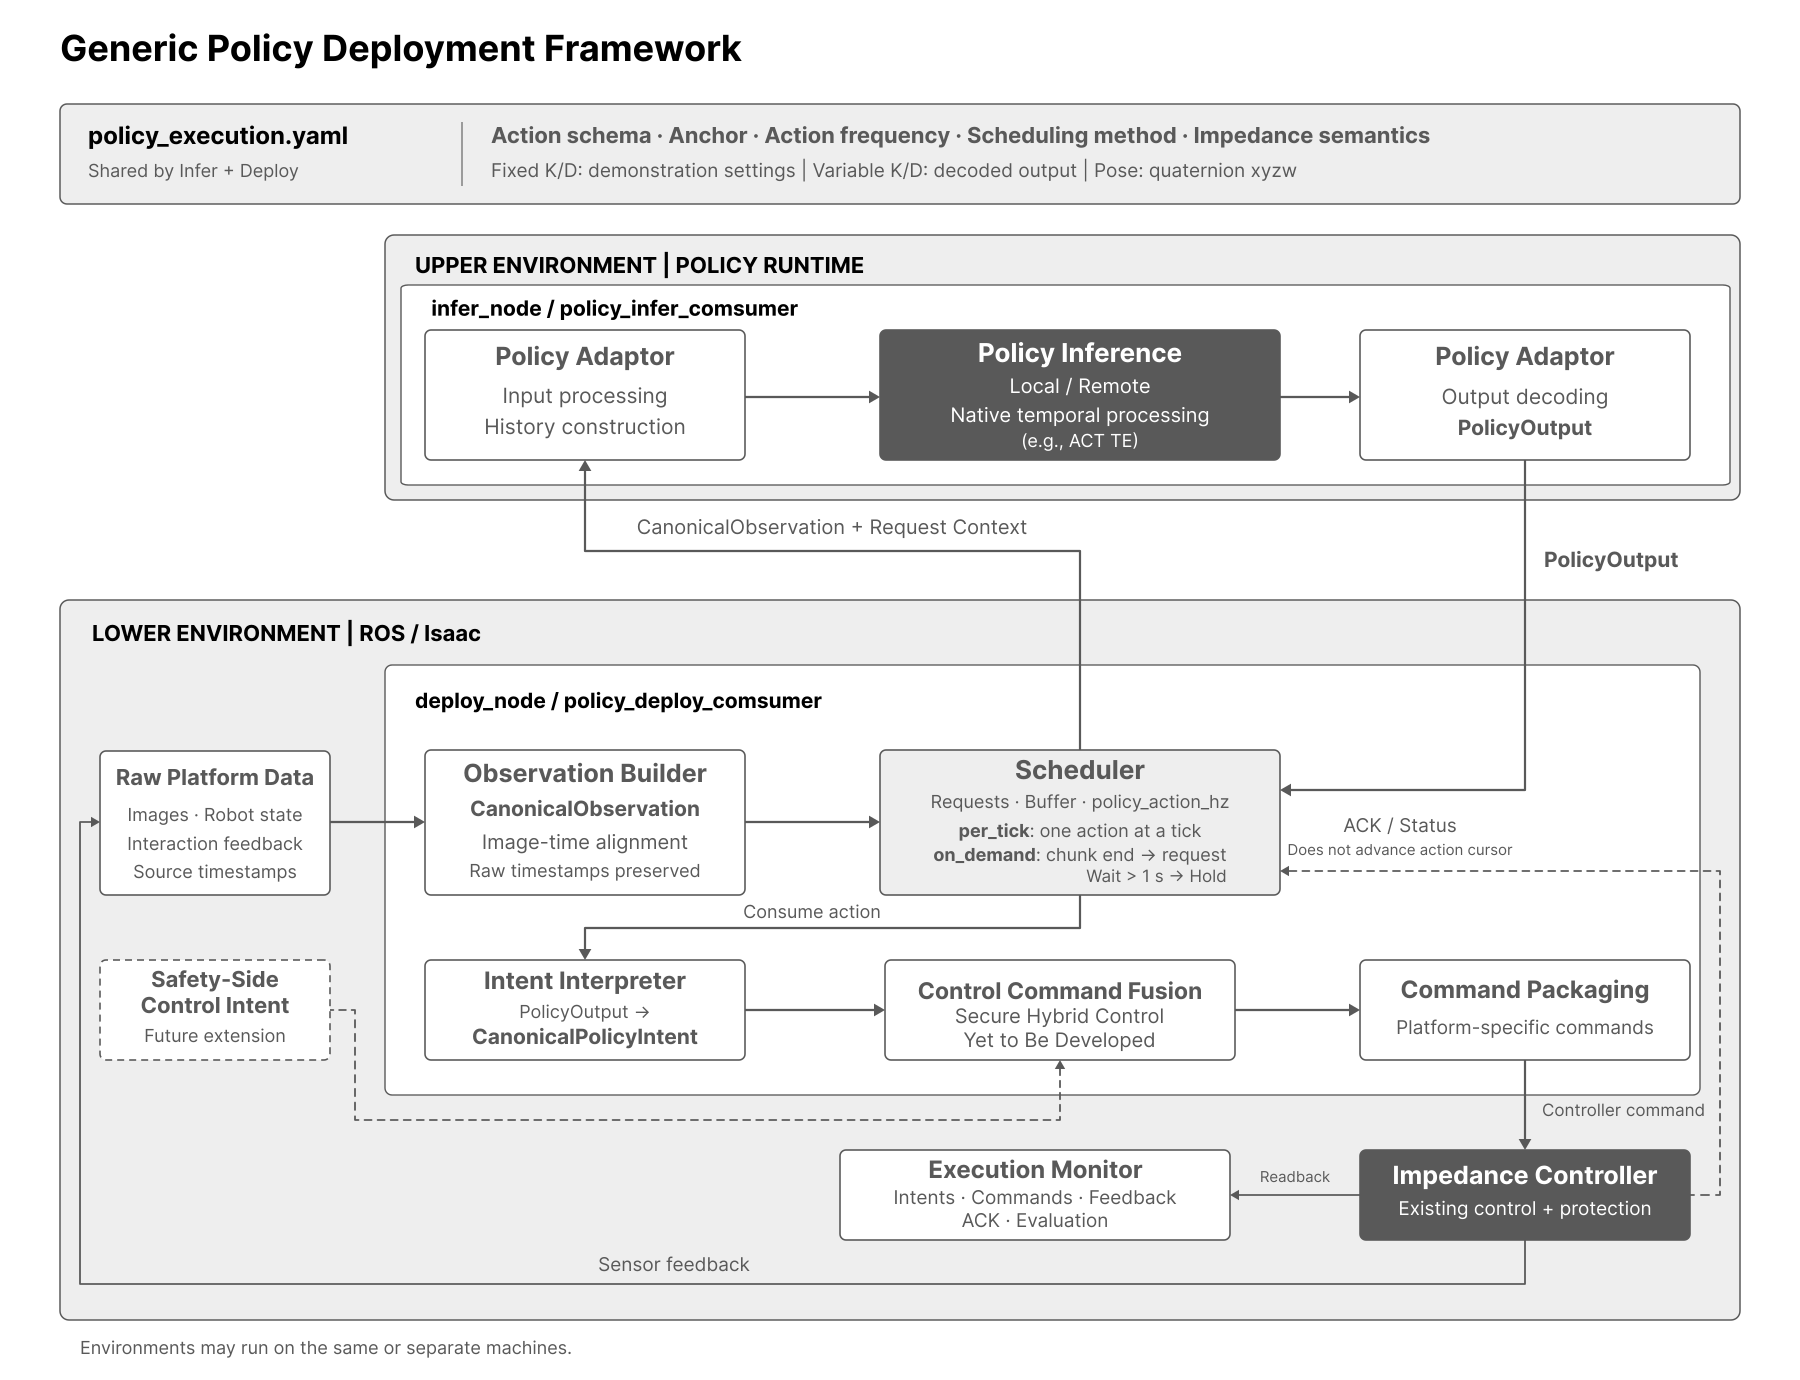
I developed a common deployment framework for running different robot learning models on the same Panda hardware and simulation platforms. It integrates ACT, Flow Matching, PI0.5, and my TRACT and CMDIR policies, with pose and variable-impedance control. The framework handles observation synchronization, inference, and action execution; demonstration conversion and run logging support the move from trained models to experiments.

自主开发通用策略部署框架,让不同的机器人学习模型能够在同一套 Panda 实机和仿真平台上运行。已接入 ACT、Flow Matching、PI0.5,以及自研的 TRACT 和 CMDIR 策略,支持位姿与变阻抗控制。框架负责观测同步、模型推理和动作执行,并配套示教数据转换与运行记录,便于训练后的模型直接进入实验。

  • policy adaptors
  • action scheduling
  • ROS / Isaac Lab
  • LeRobot datasets
General-purpose policy deployment framework. Dashed blocks indicate planned extensions.

CMDIR

Connecting retargeted controller representations with downstream learning and execution.

连接重定向控制表示与下游学习、执行。

MDIR

Replaying retargeted controllers in real contact-rich tasks.

在真实接触任务中执行重定向控制器。

TRACT

Deploying a policy across the stages of a real wiping task.

在真实擦拭任务各阶段部署学习策略。

Franka Panda impedance control

A common robot-control interface for teleoperation, demonstration replay, and learned policies.

为遥操作、示教回放和学习策略提供统一的机器人控制接口。

MASTER’S WORK / 硕士期间

Panda simulation & policy evaluation Panda 仿真与策略评估平台

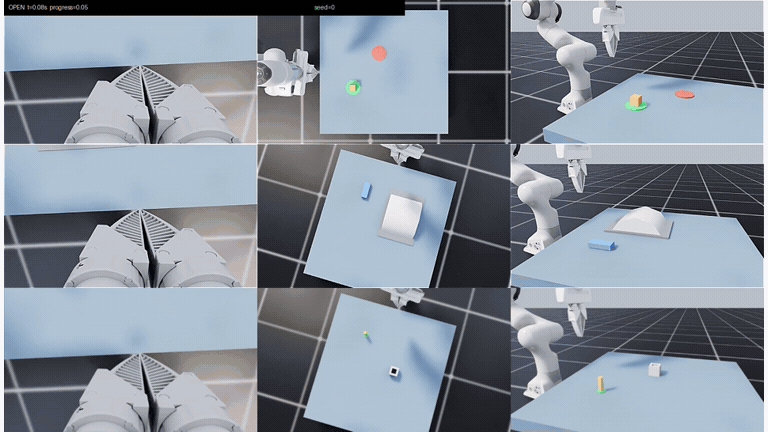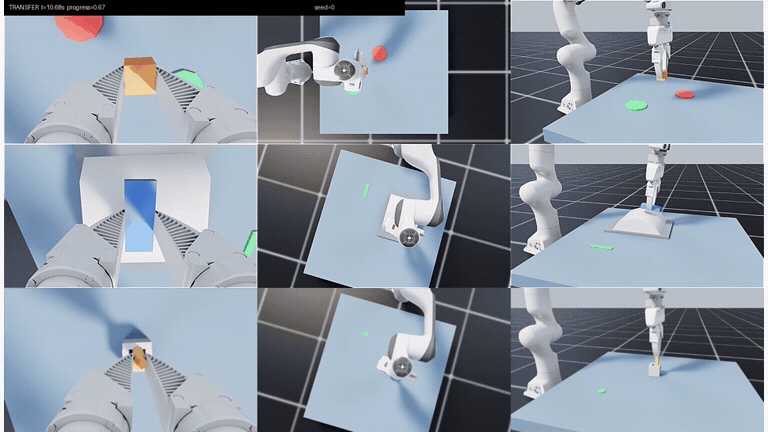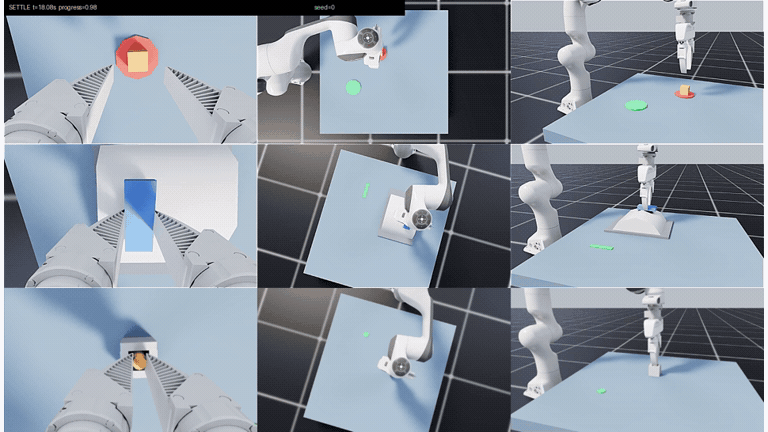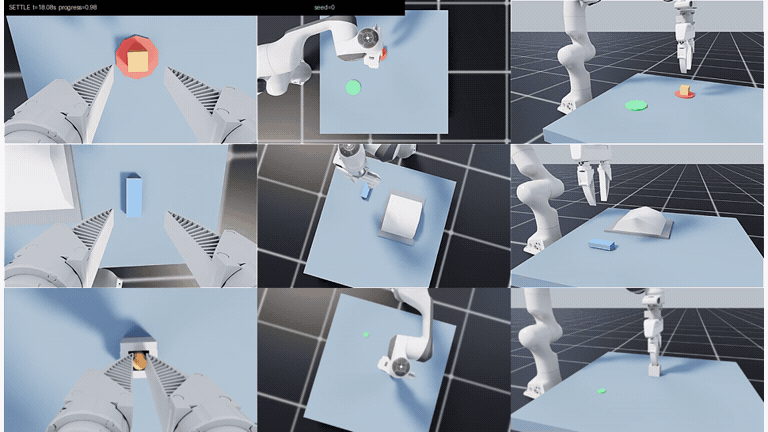
I built an Isaac Lab platform for developing and evaluating Panda controllers and learning policies in contact-rich tasks. It includes pick-and-place, planar and curved wiping, and pushing, with impedance control and policy deployment corresponding to the hardware setup. Demonstration recording, physical replay, and perturbation experiments support repeated comparisons under different contact conditions.

基于 Isaac Lab 搭建 Panda 富接触操作仿真平台,用于控制器和学习策略的开发与评估。实现抓放、平面与曲面擦拭、推动等任务,接入与实机对应的阻抗控制和策略部署流程。支持示教录制、物理回放及扰动实验,便于反复比较机器人在不同接触条件下的表现。

  • Isaac Lab
  • simulation
  • physical replay
  • policy evaluation
Top to bottom: pick-and-place, curved-surface wiping and insertion. Independent trials, 2× playback; shorter trials hold on their final frame.